Jev for robotics — a daily feed

Robot arms, drones, cars and MuJoCo simulations that people control with Jev.

114 builds
brwnsuga@BRWNSUGA1234 2 days ago
MCP orchestrator and RLM on Jev, 400 tickets
Robot judges just got an upgrade. MCP orchestrator w Code Mode, RLM built on jev. 612 tools → 77% fewer tokens 400 tickets → 5.3x cheaper, 98.8% accurate https://t.co/0SD6V1fUoM https://t.co/SahRoDNuza
5.3× cheaper98.8% accurate
Robotics 436 views
kvinsi@kv1nsiii 2 days ago
Drone courier demo with 47 decisions and 0 words generated
a drone flew a full courier run and nobody asked an LLM what to do next 47 decisions. 0 words generated. $0.0019 for the whole run, in this demo the loop is split into four jobs: > LLM - writes the route once, before takeoff > JEV - reads the state 2 times a second and returns one typed choice: CLIMB, STRAFE L, HOLD > GATE - confidence of 0.85 or higher goes straight through, anything lower wakes
$0.0019
Robotics 193 views
Nivedit Jain@niveditjain 2 days ago
Robot action policies with static and dynamic oversight
Toceta (@buildsbyaniket) Worked on policies with @failproofai and Jev for robots. Actions oversight with static and dynamic policies for the physical world. Preventing dangerous actions like handing knife to robot. https://t.co/O73kzG7Onp
Robotics 186 views
UMT Inc.@UMT_jp 3 days ago
Real-time traffic dashboard controlled by voice and text
流行りに少し遅れて、判断に特化した新しいモデル「Jev」を使い、交通量の可視化を音声や文章でリアルタイムに操作するトライアルを行いました。 ダッシュボードはよりGenerativeでパーソナルな体験になっていくのかなと思います https://t.co/fg0vMz58Kk
Robotics 175 views
Doug Brown@sdougbrown 3 days ago
Tank-driving agent built with Jev and a constrained harness
I taught jev to drive a tank 🔫 Required building quite a bit of harness to limit its decision space vs telling an llm to "just figure it out" but actually that's kind of the point of it, isn't it? Ends up that each call is ~1k input tokens vs a "tank agent" with turns growing to 60k+
Robotics 175 views
Daniiar Abdiev@DaniiarAbdiev 3 days ago
Robot pick-and-place on SO-101 from simulation-only data
I fine-tuned Qwen3.8-27B on robot simulation data only, to make Jev-style decisions from camera images. On a real SO-101 arm it completed a pick-and-place task from one command in 104 s, ~0.2 s per decision. Zero teleop. Zero real-world demos, which VLAs typically need. 🧵 https://t.co/QcZXgglxah
0.2/s
Robotics 98 views
滝澤武@TakiTake 3 days ago
Plant watering checker built with Jev and Cloudflare Workers AI
JEV使ってみたくて、植物の水やりチェッカー作ってみた。JEV自体は画像解析が出来ないから、CloudflareのWorkers AIに頼ってるので、そこは今後の課題 https://t.co/ixYmbgVIjJ https://t.co/M7CkpLFqmN
Robotics 54 views
neural nets.@cneuralnetwork 4 days ago
Jev integrated with toilet jetspray
After months of R&D, systems integration, and absolutely nobody asking for this: I have successfully integrated Jev with my toilet jetspray. It now understands context, adapts pressure dynamically, and delivers a truly personalized inference-time experience. The future of AI was never agents. It was bathroom infrastructure.
Robotics 1k views
Reinhard Zach@mrza_ch 4 days ago
Excel add-in that routes spreadsheet decisions through Jev
I put Jev behind the wheel. A small vision model in your browser describes the road. Jev, TypeSafe’s fast, cheap classifier, decides what to do. Does it stop for a child? A dog? A teddy bear? Drop them on the road and find out: https://t.co/ccWsmPEZaF https://t.co/vCz2kejaQS
Robotics 212 views
Denzii 🕊️@denziideng 4 days ago
Browser autonomous driving demo with JevPilot
我咧个去,浏览器里开自动驾驶,Jev大模型真帮你开车!🔥 想体验自动驾驶,真车不敢试,模拟器又要一堆配置💢 这个 JevPilot 开源项目,打开浏览器就能开,Jev大模型实时做决策,跟特斯拉Autopilot一个思路!👇 ✅ Jev拿到路况表,自己选走哪条、开多快 ✅ 能看到Jev的候选路线、碰撞预测和选择概率 ✅ Jev决定要不要停,安全刹车兜底防撞 ✅ Three.js做的3D路况,浏览器打开就能玩 你敢完全放手让Jev开车吗?评论区聊聊👇 🔗 https://t.co/jbMH183L9F 对自动驾驶好奇的、想玩模拟器的赶紧收!零门槛体验AI开车!🤓 #开源工具 #自动驾驶
Robotics 111 views
Basel Ashraf@BaselAshraf81 4 days ago
Jev used to make piano play correctly
We finally got @typesafeai's Jev to play the piano properly. Thanks to @LamplighterPaul 's amazing piano knowledge. https://t.co/RtOM0exnFJ
Robotics 17 views
Distill AI@DistillAI1 5 days ago
Camera-only drone simulation with Jev at 2.5Hz
🔧 Camera-only autonomous drone simulation in MuJoCo with a TypeSafe Jev judgment model running at 2.5Hz. No additional sensors — vision alone drives decisions. https://t.co/DESTshXSTu @github #DistillAI #GitHub #Robotics https://t.co/PorUiNPX7A
2.5/s
Robotics 10 views
Victor | Applied AI & Automation@vdavi_d 5 days ago
Optimal path in a virtual VTOL controlled by Jev
Handed the controls of this virtual VTOL to Jev by @typesafeai and told it to find the optimal path. A lot more decision-making happening behind the scenes than you'd think. https://t.co/0HY641FT1d
Robotics 5 views
Burke Holland@burkeholland 6 days ago
Smart home controller built in GitHub Copilot with Jev
I built a smart home controller in @GitHub Copilot with Jev. I think the hype is well deserved. It's simple. It's powerful. It's fast. It's cheap. It's going to be a core part of many applications very soon. https://t.co/aeCtXkCJBH
Robotics 2k views
HomebrewRobotics@homebrewrobots 6 days ago
Robot handoff test that recovered a moved cup with Jev
Second Jev test. One instruction: return all the cups. The plan was a right-arm handoff. We moved the cup mid-task. Jev from @typesafeai dropped the handoff, picked it up with the left arm, and finished the task. https://t.co/LyWlqtNChF
Robotics 481 views
a2c@_a_2_c_ 6 days ago
Drone control in simulation with Jev
Jevの便利な使い方じぇんじぇん思いつかないけど、まさかDroneの操縦させたらこんなに上手くいくと思わなかった。Simだから出来てるけど自己位置と障害物ちゃんと取れればほんとにこの精度で飛べるのか・・ https://t.co/CTVhXbhnRY
Robotics 81 views
metr0x@metrox_eth 6 days ago
CPU MuJoCo simulator with recorded Jev missions
Published! The CPU MuJoCo simulator, MOSS MJCF + meshes, and all three recorded Jev missions are here: https://t.co/hkLs3DnV2v Start with model/moss_robot.xml and model/meshes/ to add the body to your stage. The README includes a no-key replay command and the integration details. Base motion is currently a simplified X slide; grasping and dropping use physical contacts. Would love to see MOSS alon
Robotics 53 views
Supreeth Ravi@supreeth___ravi 6 days ago
Unitree G1 kitchen routines steered by Laya in 46 ms
Took the Jev-style decision call into a kitchen: A Unitree G1 humanoid runs errands while Laya, a 0.3B open-weight decision model, picks every move in ~46 ms. Fine-tuned and run fully on open source, on a laptop. Matches a hand-built planner in a kitchen it never saw. https://t.co/Pk7B1kPbMH
46 ms
Robotics 21 views
Arun Venkatadri@ArunVenkatadri 6 days ago
nuScenes robot labeling with Jev, 19 s in 2 s out
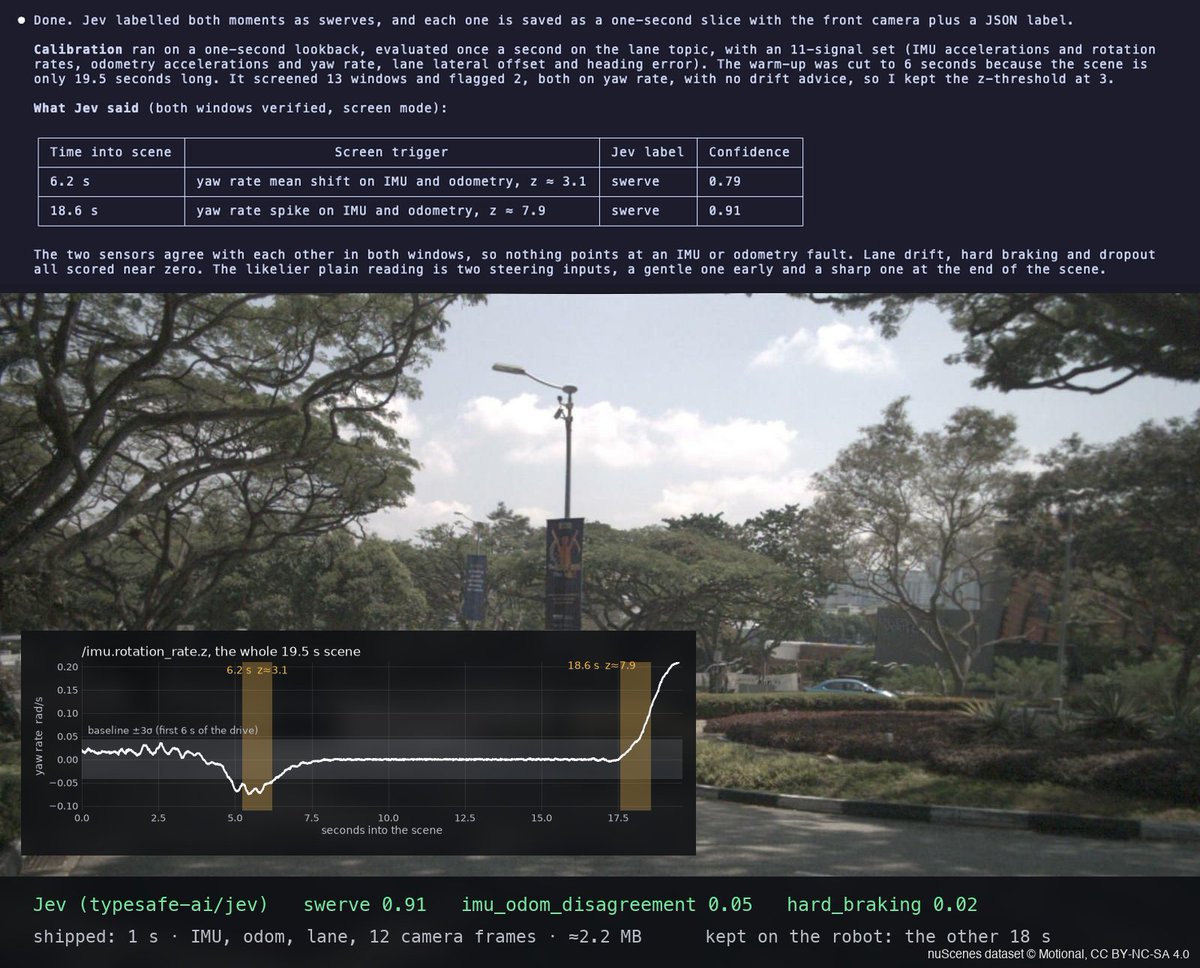
"We don't know what we don't know." Bagel 2.3.0 + @typesafeai 's Jev (beta): learn normal on the robot, let Jev name what isn't, ship only those seconds, labelled. Everything else stays behind. One sentence, no YAML. Real nuScenes drive below: 19 s in, 2 s out, both "swerve". (non-commercial use) Free, Apache-2.0 ⭐ https://t.co/6WXujWR4oL Drive from the nuScenes dataset © Motional (CC BY-NC-SA 4.0
Robotics 18 views
Morty@0xMortyx Sep 23
Swarm controller for 300 agents with 12,480 Jev decisions
I just built a Jev X Swarm Controller and put 300 agents on autopilot for 6 minutes. 300 K3 workers on autopilot. 6 minutes. 12,480 turns. Jev made a decision on every one of them. 91 reached me. A swarm knows how to execute. It does not know when to stop. every turn gets 6 typed questions: is this result good enough, is there new information, is this the same state as last turn. then one action:
300/s12,480 items
Robotics 364 views
MOH∆M∆D REZ∆@Roa1375 Sep 23
Built a raw Jev-based bot with OpenRouter
@ErFUN_KH من ی ربات نوشتم با یه نسخه خام از jev کنارشم یه openrouter گذاشتم چیز‌یادش بده ولی خب این نسخه خیلی خله .. هیچی نمیدونه ... ترین نشده https://t.co/5SwMp492ub
Robotics 198 views
Alex@AlexanderTw33ts Sep 23
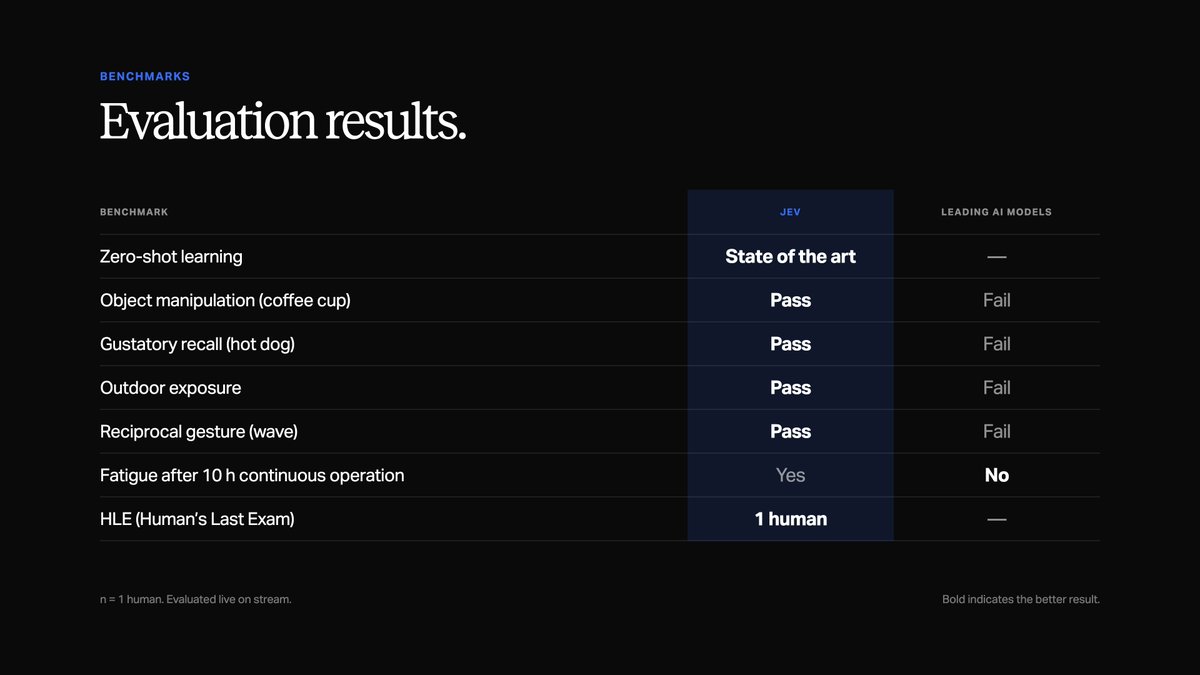
Internal eval of Jev on object manipulation and recall
On our internal evals, Jev outperforms leading AI models on object manipulation, gustatory recall, and outdoor exposure. Evaluated live on stream. n = 1. https://t.co/tg32gwVTVK
Robotics 58 views
Engineermaxxing@engmaxxing Sep 23
Real-time robot reward generation hackathon prototype
@chelseabfinn Amazing work! We recently processed this paper for anyone to read, listen or watch https://t.co/wluMvPTlwV We also attempted real time robot reward generation to tackle this latency issue using Jev in a 90 minute hackathon last weekend. Here is the post and full write up https://t.co/9H2j3E1Mfc
Robotics 40 views
Prachi Sethi@prachi1615 Sep 22
OM1 and Isaac Sim navigation with Jev decision model
Last week, @typesafeai launched an early access version of Jev, a new decision-making model. Now that it’s available to everyone, I want to share what I found after plugging Jev into @openmind’s OM1 and using the model to navigate our Go2 on @nvidia’s Isaac Sim. https://t.co/P3zOc4O2xQ
Robotics 2k views
Felipe Mautner@felipe_mautner Sep 22
Jev-controlled rocket in KSP, pitch throttle and staging
Jev just put Jeb into orbit! I wanted to see if Jev could control a rocket in KSP, turns out it can! Jev controlled pitch, throttle and staging. Jeb did his part too by smiling a whole bunch. thank you @typesafeai for giving Jeb its AI friend. https://t.co/URDQhPNRck
Robotics 200 views
Automata Room@automataroom Sep 22
Unitree G1 crate-carrying run judged by Jev
@typesafeai we are tested Jev as the decision maker for a Unitree G1 humanoid in Automata Room. The task: carry 4 crates to a storage rack, one at a time, then return to the entrance. Fewer, shorter trips score better. Full run below 👇 https://t.co/xpliAUN5fR
Robotics 111 views
Jad Fayad@Jadfyd Sep 21
PyBullet robot brain with Jev reflexes under 100ms
Built a System 1 + System 2 robot brain using @typesafeai's Jev in PyBullet. 🧠 Claude: Generates the high-level plan to stack cubes. ⚡ Jev: Acts as the split-second reflex layer, evaluating sim states in <100ms to adapt. Fast, schema-safe neurosymbolic robotics in action. https://t.co/WVNB1aqo7n
Robotics 35k views
vechen@miu21590 Sep 21
Codex CLI workflow using Jev for per-step reasoning control
If this gets traction, I'll open-source it on my GitHub https://t.co/kQTfGvPVQy (and post again on X to notify). I've been using it for real work in Codex CLI. It uses Codex CLI's experimental per-step settings to change reasoning effort before the next GPT-6 generation. After tool results, Jev gets the task, published reasoning/progress summaries, and the last six tool calls with bounded outputs.
Robotics 27k views
Harvey Michael Pratt@npceo_ Sep 21
Autonomous driving test with Jev, world model and segmentation
Can Jev drive a car despite not being able to see? I gave Jev access to an unreleased world model used to train self-driving cars and a local segmentation model to see if it could drive autonomously. TLDR: Kinda? It's a little Crazy Taxi - but kinda amazing this works at all. https://t.co/NKoe7RqFIe
Robotics 16k views
posi_posi@posi_posi8 Sep 21
Ran 172 robot arm pick-and-place experiments with Jev
AI Solutions Lab | Researcher: Luca 寝ている間に、Claude Code にロボットアーム(SO-101)の実験を任せた。 一晩で172回、掴んで運ぶ実験を自分で設計して回していた。100回連続の掴みは成功97回、1回17.8秒、途中停止なし。集計も不具合の修正も自分でやっていた。 ・Jevのユースケース 「ピンクを含む物は左へ」「丸い物は必ず中央へ」のような言葉のルール12種で、仕分けの行き先を判断させた。俯瞰カメラが位置と色を見て、ローカルのQwen3.5 4Bが種類を答え(0.8秒)、Jevがルールを当てはめる(0.6秒)。72回すべて、選んだ区画へ運べた。ルールが答えを定めている65回は全問正解。 弱かったのはJevに渡す側の目だった。同じボールが置き場所によって「緑」「ピンク」と別の色に読まれ、VLMも71回中17回「フィジェットスピナー」と答
Robotics 9k views
Franco@crypto_dev_1 Sep 21
Robot arm controlled with natural language commands via Jev
LE HABLO A UN BRAZO ROBÓT IGUAL QUE A UNA PERSONA 🤖🚀 Usando @typesafeai Jev el robot ahora puede entender frases como Abri la mano Anda al techo Estirate lo máximo que puedas Demo arranca en 1:25 Venimos a pleno preparándonos para el @ArgentinaSpace https://t.co/qOTkch12gN
Robotics 5k views
xiao hu@huxiao93612565 Sep 21
Built a Jev-inspired robot sim with 10/10 recovery success
What happens when the target moves mid pick-and-place? Open-source, Jev-inspired sim: local 2B model + PiPER robot in MuJoCo. Cube relocated 3x per run; robot detects, interrupts, recovers. 10/10 seeds succeed, 32.6 ms median decision latency. https://t.co/HIdSDIXgqh https://t.co/cr60W65388
32.6 ms
Robotics 3k views
Robert@rodenlab Sep 21
Simulated nervous system driving a robot with Jev
Jev is INSANE. I connected it to a bio-inspired robot running off a simulated nervous system. Neural activity gets fed into Jev, Jev makes a rapid decision, and that decision gets translated into physical movement. https://t.co/EH6CmHezqm
Robotics 2k views
HomebrewRobotics@homebrewrobots Sep 21
Humanoid cup-stacking recovery planner with 6 options and 65% confidence
We moved a cup while our humanoid was stacking a cup pyramid. Jev from @typesafeai chose the next move: set down the held cup, replan, finish the stack. 6 recovery options. 65% confidence. https://t.co/if6e4TEBNP
65% accurate
Robotics 822 views
Andrew Blumson@Andrew_Blumson Sep 21
Drone action chooser for a rescue sim, 208 ms average response
Just for fun - I give the station a priority. Jev reads the situation and chooses the drone’s next action. Built on @Replit with TypeSafe’s Jev and native WebGPU. Jev assesses the station, evaluates evacuation risk and urgency, and chooses the drone’s next action. I’m controlling the camera. In this run: 208 ms average Jev response, including network time. All 12 crew rescued. No email classificat
208 ms
Robotics 696 views
kkonline.org@krishnakhanna Sep 21
OpenJev autonomous self-driving simulation integration
Implemented with #Openjev using #Codiv for Autonomous Self Driving Simulation. Based on https://t.co/X4aAbzRADY #Jev Track the decisions Code (Apache-2.0): https://t.co/tpfbk5wsjk Free hosted API: https://t.co/nQX2S6urCY https://t.co/rnWEY8N5kg
Robotics 350 views
78 more below

Submit a build

Paste the link to your post on X about something you built with Jev. We check the link right away. The next update, within about 4 hours, adds the card if the post shows your build.